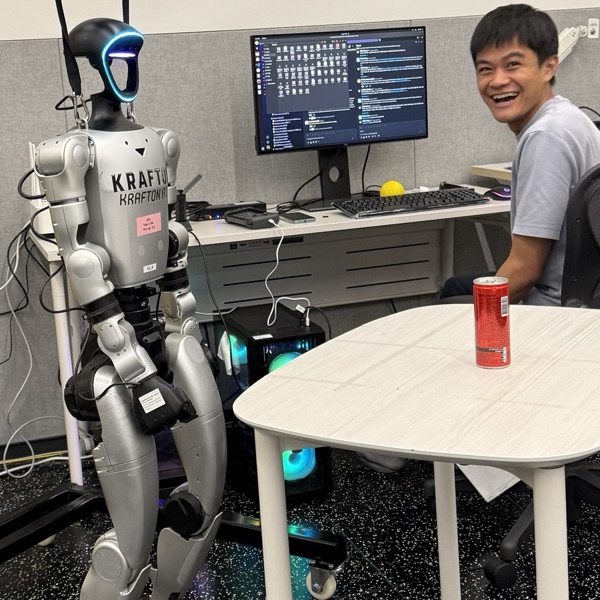
Tri Wahyu Guntara
Applied Research Engineer (RL), KRAFTON
I build reinforcement learning agents at KRAFTON, first for games (PUBG) and now for humanoid robots, and I am currently on dispatch to Ludo Robotics, KRAFTON's robotics spin-off. I did my master's at KAIST, advised by Kee-Eung Kim.
Experience
2026.07 - Present
Research Engineer,
Ludo Robotics
Seoul, South Korea
Concurrent role, on dispatch from KRAFTON
- Built a Pico VR teleoperation system for the Unitree G1 humanoid with locomotion, waist, and arm control, used to collect real-robot data
- Fine-tuned vision-language-action (VLA) models on the collected data and deployed them on the Unitree G1
- Systems integration for Ludi 0.1, an agentic system for socially intelligent robots, on the real robot
2024.11 - Present
Applied Research Engineer (RL),
KRAFTON Inc.
Seoul, South Korea
2025.12 - Present
Physical AI Team
- Trained RL agents for non-perceptive locomotion, and for perceptive navigation on top of the locomotion policy, on the Unitree G1 humanoid
- Fine-tuned GR00T and π-family vision-language-action (VLA) models on the AgiBot G1 humanoid in simulation and added a HAMLET memory module, which significantly improved task success
- Owned the simulation evaluation pipeline: ported GenieSim, an asynchronous Isaac Sim environment for the AgiBot G1, to a synchronous Isaac Lab implementation that runs parallel instances for scalable evaluation
2024.11 - 2025.11
Reinforcement Learning Team
- Trained an RL agent for the PUBG parachute-landing task to replace the rule-based bot, cutting mean landing error from 40 / 60 / 523 m to 18 / 19 / 24 m on short (<1 km), medium (1–1.7 km), and far (>1.7 km) drops
- Trained an RL agent that plays the full PUBG game, deployed as the PUBG AI Chicken Challenge, a limited-time player-vs-AI event at PUBG UNITED: HOMECOMING (Dec 2025 – Jan 2026)
- Early development of a full-game RL agent for PUBG: Blindspot, a top-down tactical shooter in development at KRAFTON
2022.01 - 2024.08
Graduate Student Research Assistant,
Korea Advanced Institute of Science and Technology (KAIST)
South Korea
2023.01 - 2024.08
Artificial Intelligence & Probabilistic Reasoning Lab
- Reinforcement learning and thesis project under the advisory of Prof. Kee-Eung Kim
2022.01 - 2022.12
Autonomous Vehicles and Embedded Systems Lab
- Self-driving car and reinforcement learning under the advisory of Prof. Seung-Hyun Kong
2019.06 - 2019.12
Research Scientist Intern,
Kata.ai
Indonesia
- Benchmarked models on Indonesian sequence labeling tasks (POS tagging, NER, SRL)
- Collected scattered Indonesian-English data and benchmarked models on neural machine translation
Publications
2026
-
P2Ludi 0.1: An Agentic System for Socially Intelligent RobotsLudo Robotics Technical Report
-
C2ACPO: Agent-Chained Policy Optimization for Multi-Agent Reinforcement LearningReinforcement Learning Conference (RLC) 2026
2025
-
P1CLEAR: An Information-Theoretic Framework for Distraction-Free Representation Learning in Visual Offline RLPreprint
2024
-
C1Kernel Metric Learning for In-Sample Off-Policy Evaluation of Deterministic RL PoliciesICLR 2024
2020
-
W1Benchmarking Multidomain English-Indonesian Machine TranslationLREC Workshop on Building and Using Comparable Corpora (BUCC) 2020
Education
2021.09 - 2024.08
M.S. in Artificial Intelligence,
Korea Advanced Institute of Science and Technology (KAIST)
(Advisor: Kee-Eung Kim)
Thesis: Information-Theoretic Distraction-Free Representation Learning for Visual Offline RL
2016.09 - 2020.08
B.Eng. in Electrical Engineering,
Universitas Indonesia
Projects
-
Ludi 0.1: An Agentic System for Socially Intelligent Robots
-
CLEAR: Controllable Latent State Extractor for Visual Offline RL
-
PALAPA-707: An Autonomous VTOL Drone for the Indonesia Flying Robot Contest 2018
Scholarships & Awards
2021.09 - 2023.08
Hyundai Motor Chung Mong-Koo Global Scholarship
Full scholarship for the duration of the 2-year master's study at KAIST
2018.11
Indonesia Flying Robot Contest 2018 — Honorable Mention
Vertical take-off and landing (VTOL) category